[SoRo 2022] Sensing without a Sensor
This is an excerpt
Proprioception is the ability of the human body to sense movement, action and location. It is what enables us to dribble a basketball without looking at it. It is the ability to move without thinking. “Sixth sense” in some sense (no pun intended).
The easiest and most direct way to enable proprioception in robots is to install and use sensors. A force sensor to measure point forces, a temperature sensor to measure heat, a flex sensor to measure the degree of bending, a torque sensor to measure torque generated, so on and so forth. This means that in most instances, to sense 10 elements, 10 individual sensors are needed. This is not usually a problem for most robotic applications, but as the size of the robot gets smaller, the amount of space and volume available for sensor placement gets smaller too. So if 10 sensors are needed but only 5 can be installed, that then becomes a problem.
Then I thought, why not give robots a “brain” then? You know how our human brain can derive solutions when given information, or lack thereof? Like how other senses heighten in a deaf or blind person. Essentially, I want to program a brain that can derive information in the absence of some. The keyword here is some.
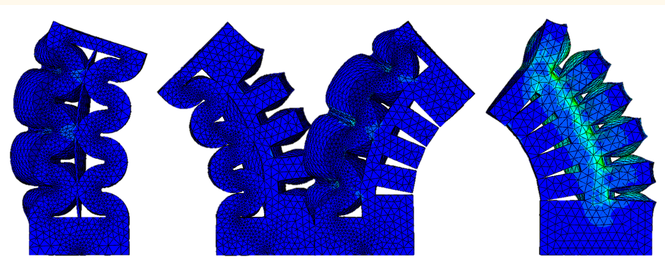
In the soft actuators that I have designed so far, pressure sensors are absolutely necessary. They are needed to prevent the actuators from exploding, quite literally. My idea is hence, to use pressure readings to derive multimodal information. To me, this concept is intuitive.